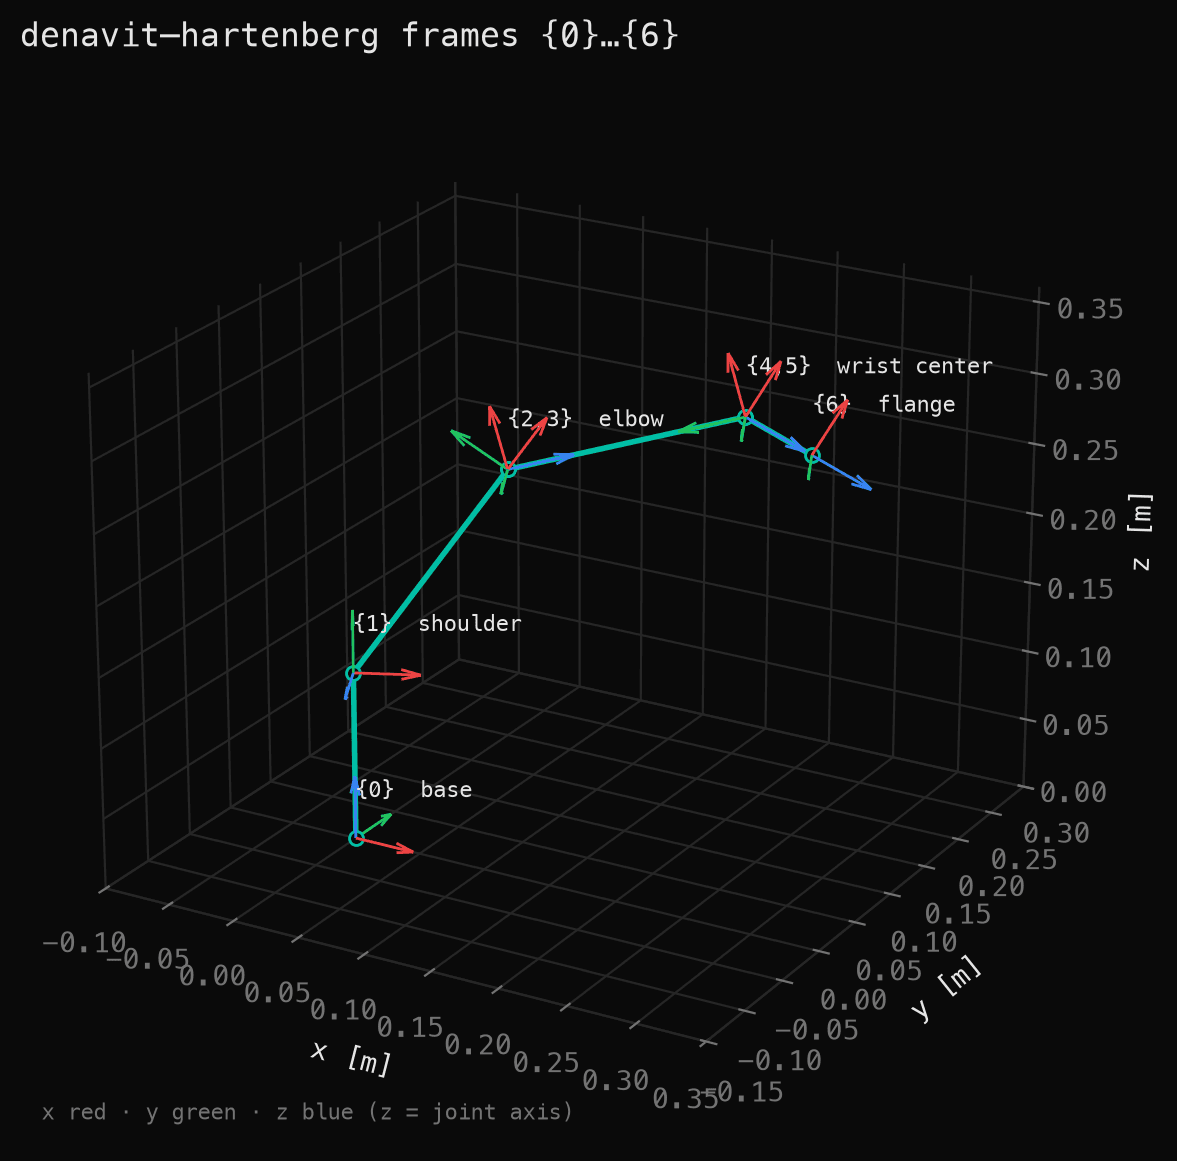
building a $500 6-dof robot arm: the plan
A six-axis robot arm I design, print, wire and program myself for $500: requirements, architecture, Denavit–Hartenberg geometry and the budget. Part 1 of a series.
10/16/20266 min read
2 views
Computational explorations and scientific visualizations
Computational explorations and scientific visualizations
A six-axis robot arm I design, print, wire and program myself for $500: requirements, architecture, Denavit–Hartenberg geometry and the budget. Part 1 of a series.
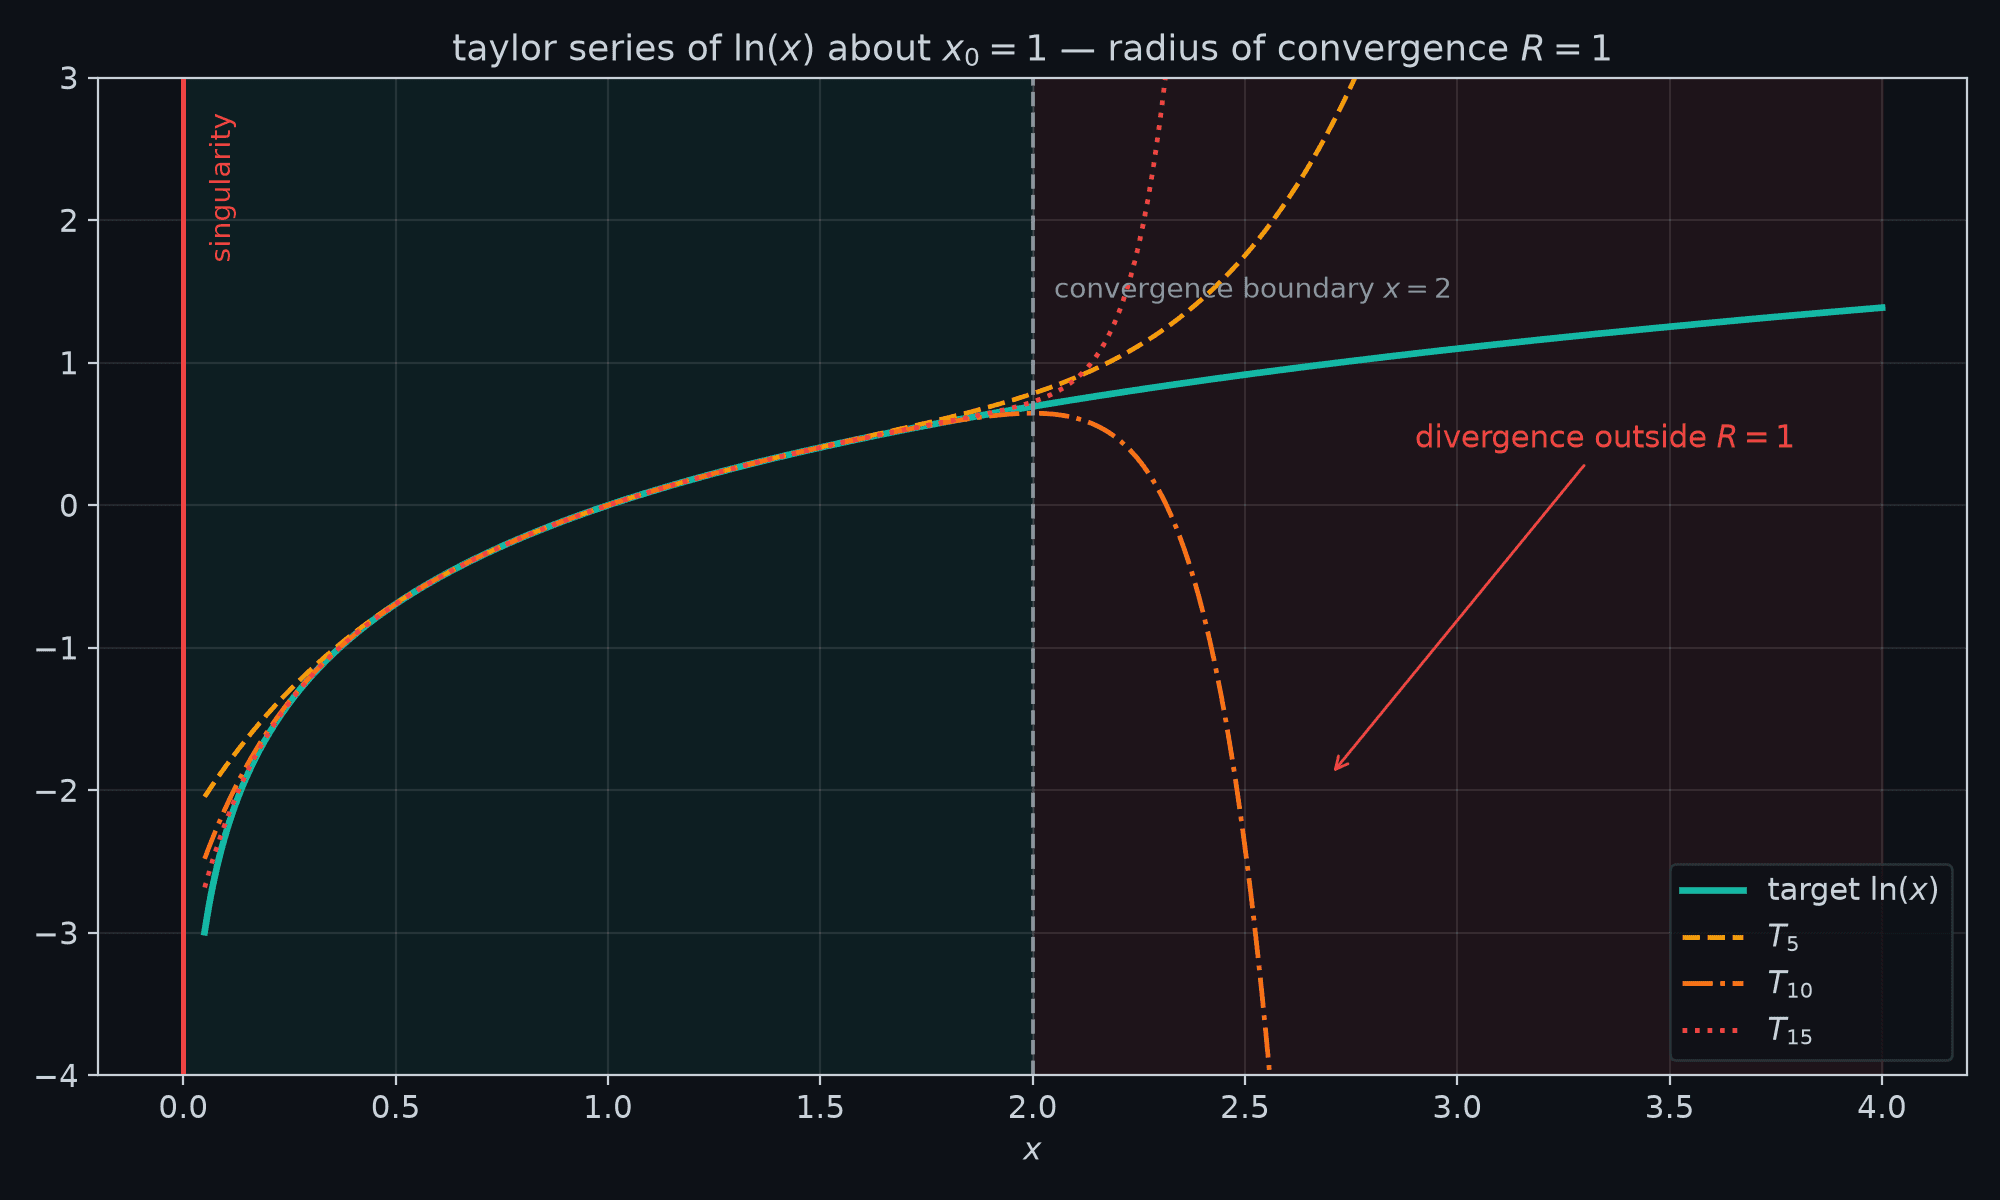
Watching polynomials wrap around sin, cos and ln: factorial-fast convergence for entire functions, and the hard wall of the convergence radius where adding terms makes things worse.
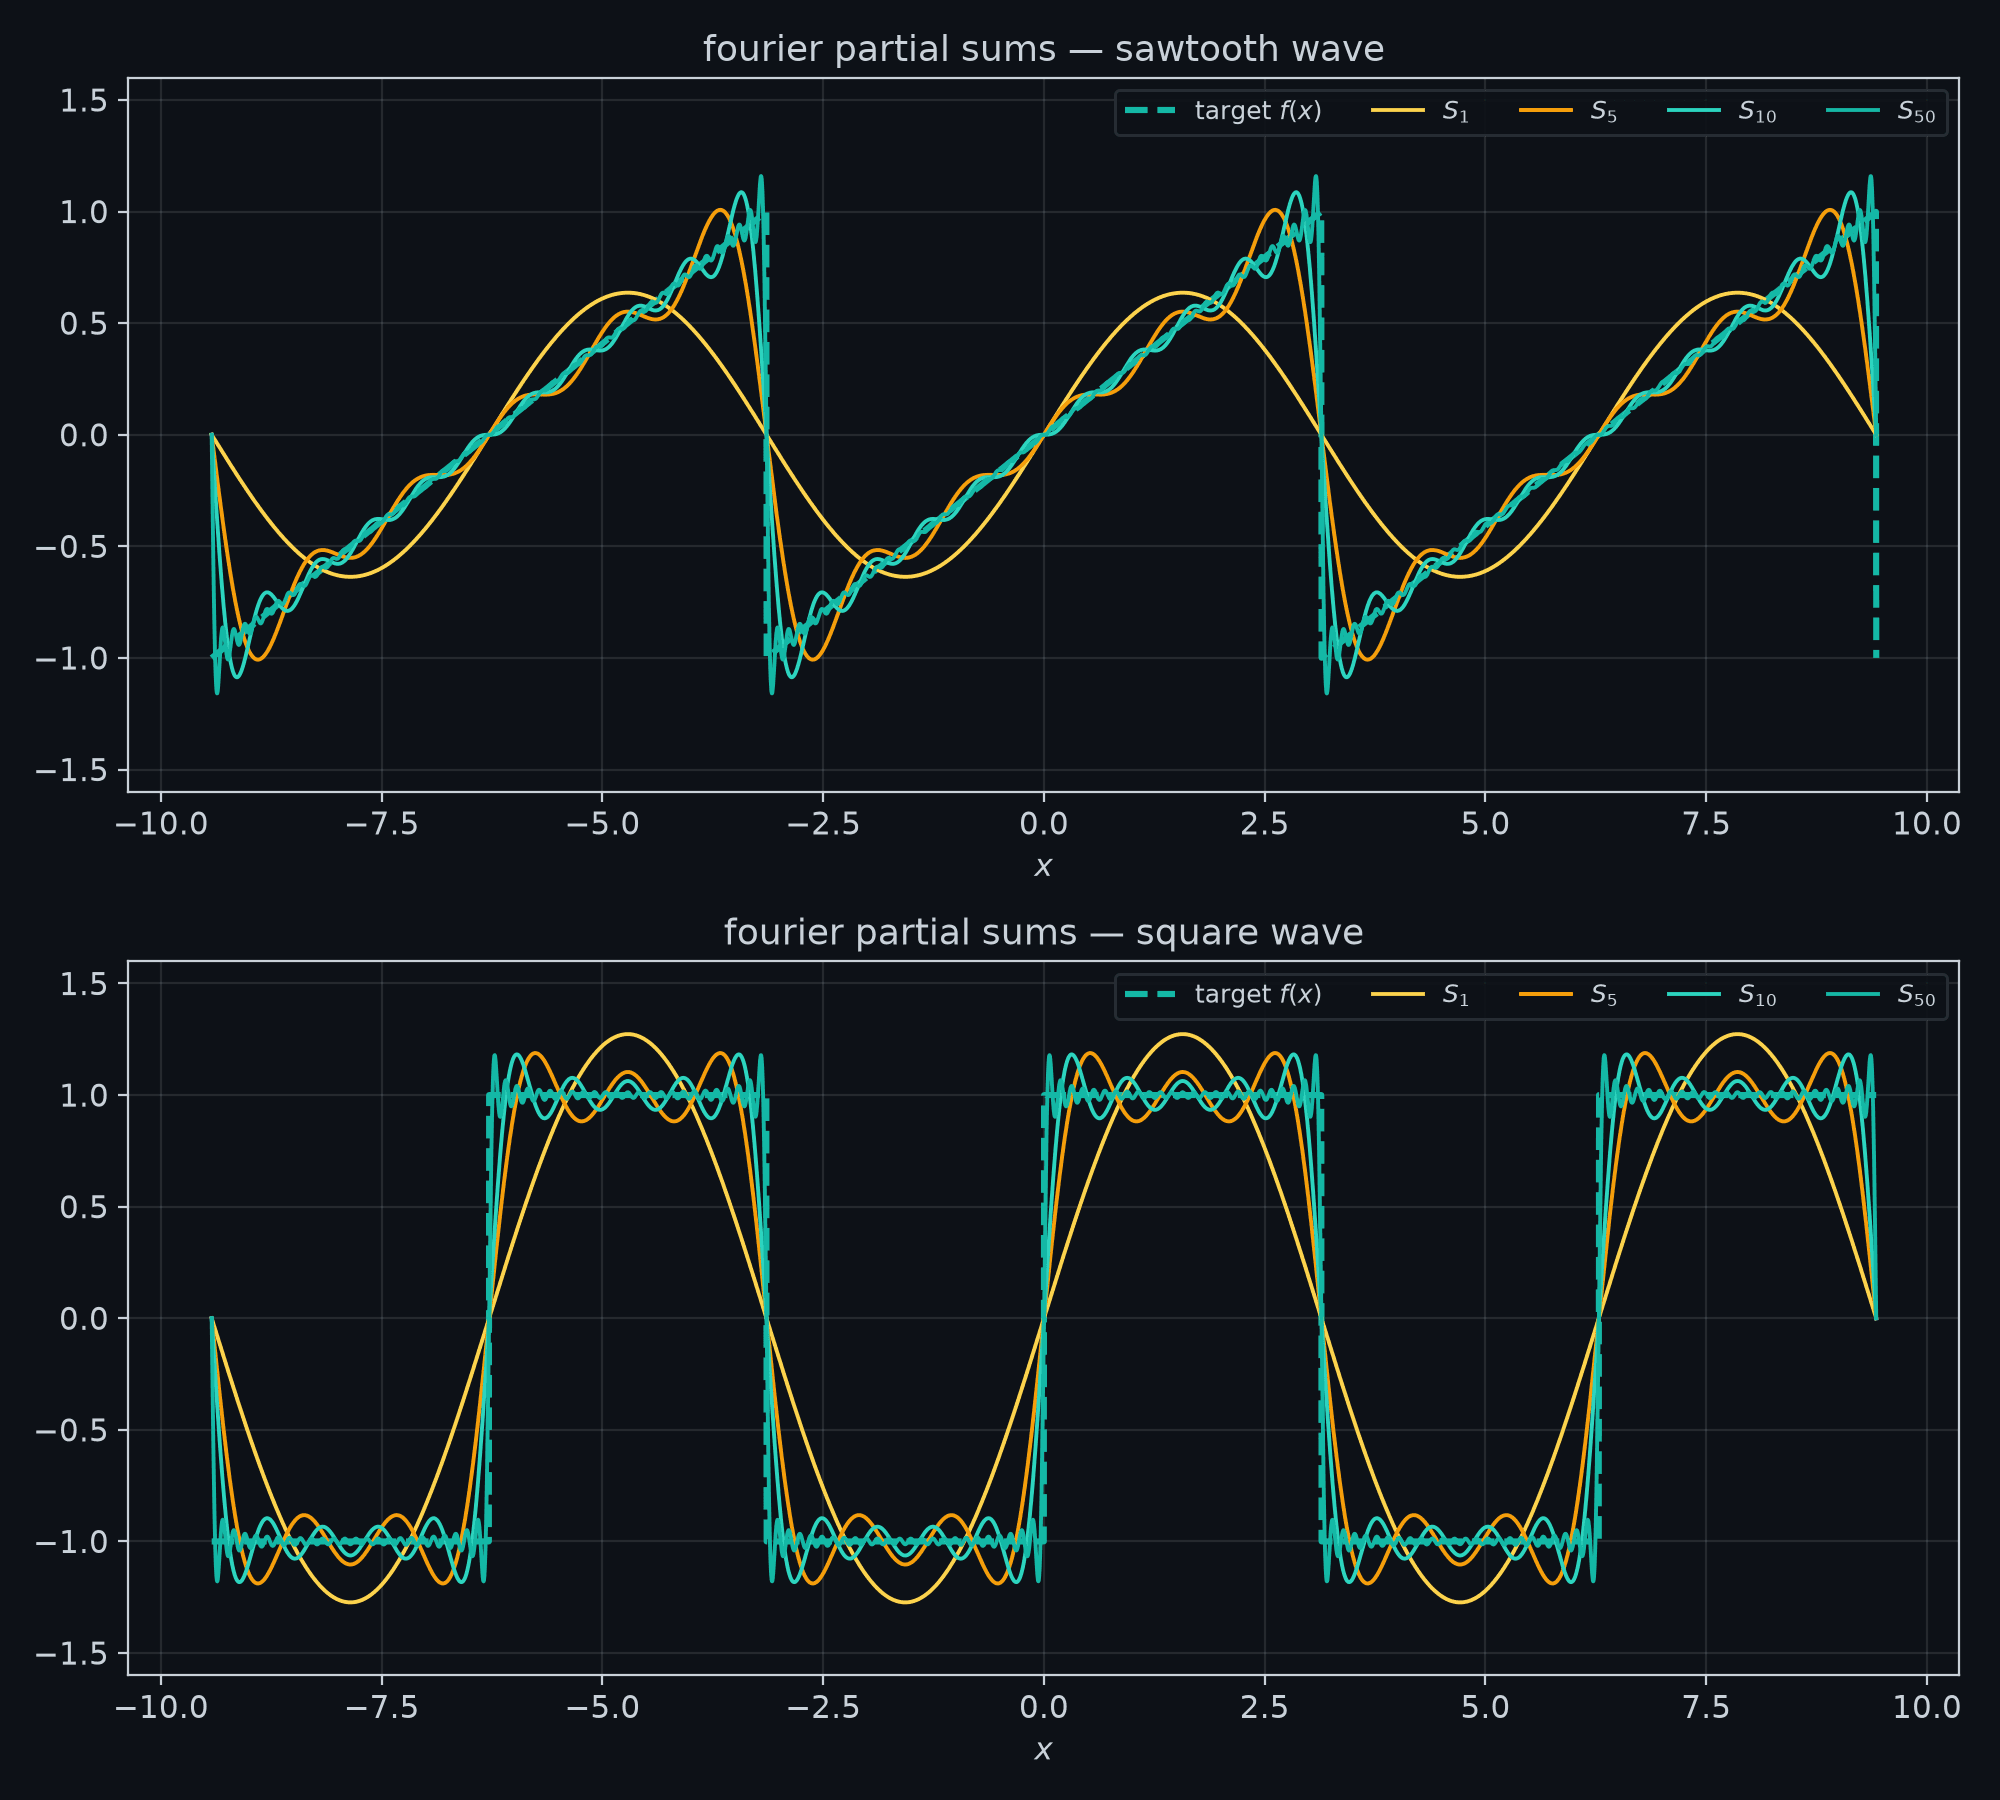
Rebuilding sawtooth and square waves out of pure sines: animated partial sums, the stubborn 9% Gibbs overshoot, and a measured convergence rate — all validated numerically before plotting.
I gave TorqueHash the ability to stream data using Rust's Write trait - turning it from a byte-slice toy into a composable I/O component with a real CLI.
I built a minimal cryptographic hash function from scratch in Rust using sponge construction and ARX operations — not to replace SHA-256, but to understand what's inside one.